Sarvesh Prasanth Venkatesan
I make robots move and act in the real world, using reinforcement learning, imitation learning, and vision-language-action models to take policies from simulation to real hardware. Currently, I'm an M.S. student at USC working on humanoid control with Prof. Quan Nguyen, and an RL research intern at PlusAI.
Education & more ↓
Interests
Experience
RL Planner Research Intern
PlusAI,
Santa Clara, CA
Aug 2026 – Present
RL safety layer for autonomous-driving in long-tail scenarios.
Graduate Researcher
Dynamic Robotics and Control Laboratory,
University of Southern California
Dec 2025 – Present · Advisor: Prof. Quan Nguyen
Humanoid robot learning — perceptive whole-body control (ViBe) and VLA post-training.
Project Associate
Stochastic Robotics Lab,
Indian Institute of Science, Bengaluru
Jul 2024 – Aug 2025 · Advisor: Prof. Shishir Kolathaya
Quadruped locomotion — a cross-embodiment generalist policy (GRoQ-LoCO) and sim-to-real RL
on the 70 kg Stoch5.
Project Associate
Mobile Robotics Lab,
Indian Institute of Science, Bengaluru
Sep 2023 – Jun 2024 · Advisor: Prof. Debashish Ghose
UAV–UGV multi-robot inspection and multi-object tracking (LocalizeSORT).
Research Intern
Centre for Non-Destructive Evaluation,
IIT Madras
Sep 2022 – Jul 2023 · Advisor: Prof. Prabhu Rajagopal
Navigation and pick-and-place for a shopping-assistance robot.
Publications
@article{krishna2026vibe,
  title={ViBe: Visual Behavior Adaptation for Perceptive Humanoid Whole-Body Control},
  author={Krishna, Lokesh and Venkatesan, Sarvesh and Zhang, An and Nguyen, Quan},
  journal={arXiv preprint arXiv:2609.09918},
  year={2026}
}
@article{pp2025groq,
  title={GRoQ-LoCO: Generalist and Robot-agnostic Quadruped Locomotion Control using Offline Datasets},
  author={PP, Narayanan and Venkatesan, Sarvesh Prasanth and Reddy, Srinivas Kantha and Kolathaya, Shishir},
  journal={arXiv preprint arXiv:2505.10973},
  year={2025}
}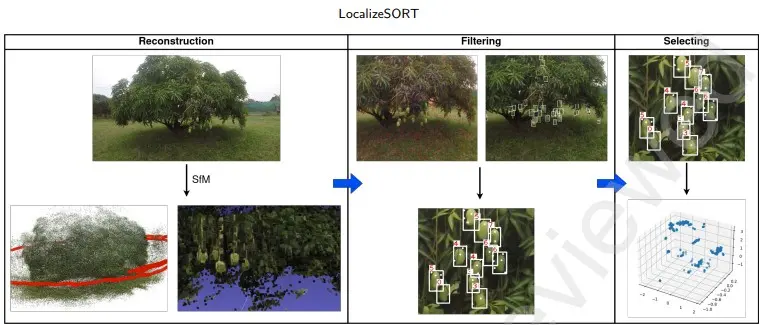
@article{vemuru2024yield,
  title={Yield prediction and counting using world coordinates},
  author={Vemuru, Srihari and Ankit, Kumar and Venkatesan, Sarvesh Prasanth and Ghose, Debasish and Kolathaya, Shishir},
  journal={Available at SSRN 4829514},
  year={2024}
}
Education
M.S. in Electrical and Computer Engineering — Machine Learning
2025 – 2027
Los Angeles, CA
B.Tech. in Electronics and Communication Engineering
2019 – 2023
Vellore, India